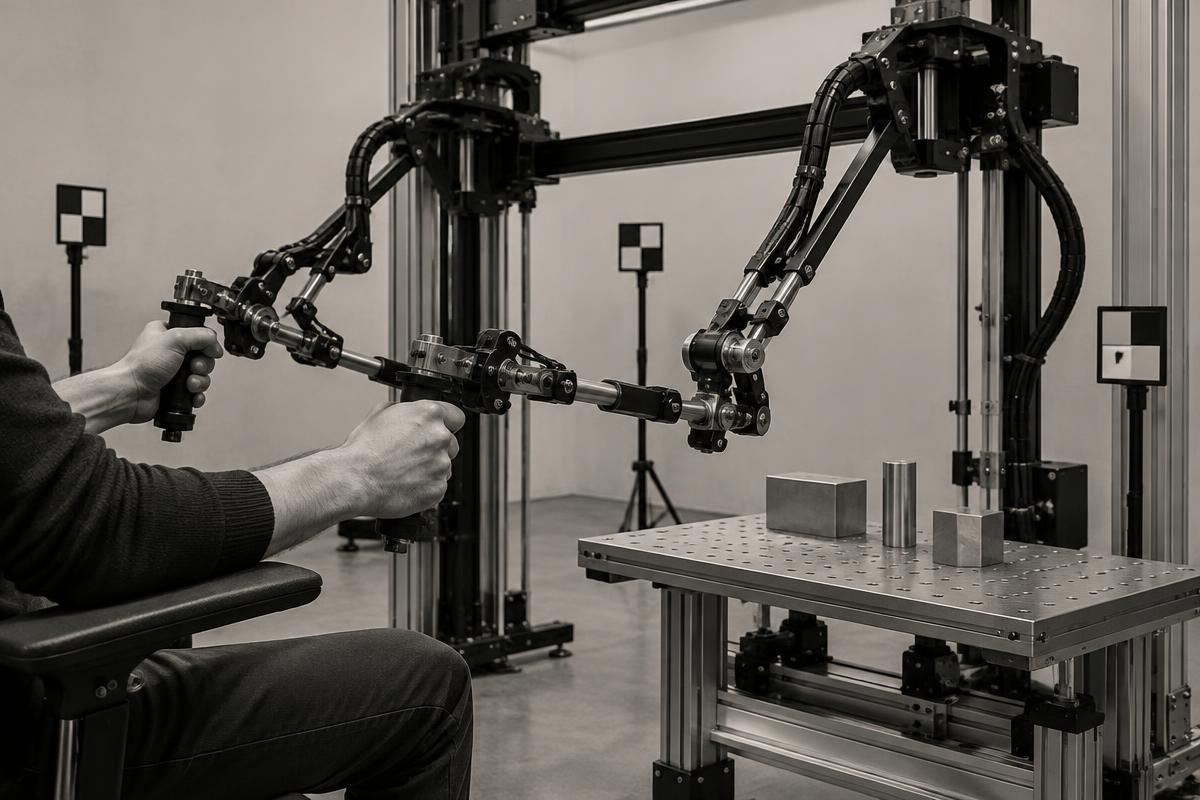
Teleoperation demonstrations
Human-controlled robot demonstrations captured at the task level.
Demonstrations establish the task. Takeovers show where autonomy fails. Recovery turns that failure into a useful training signal.
Human-controlled robot demonstrations captured at the task level.
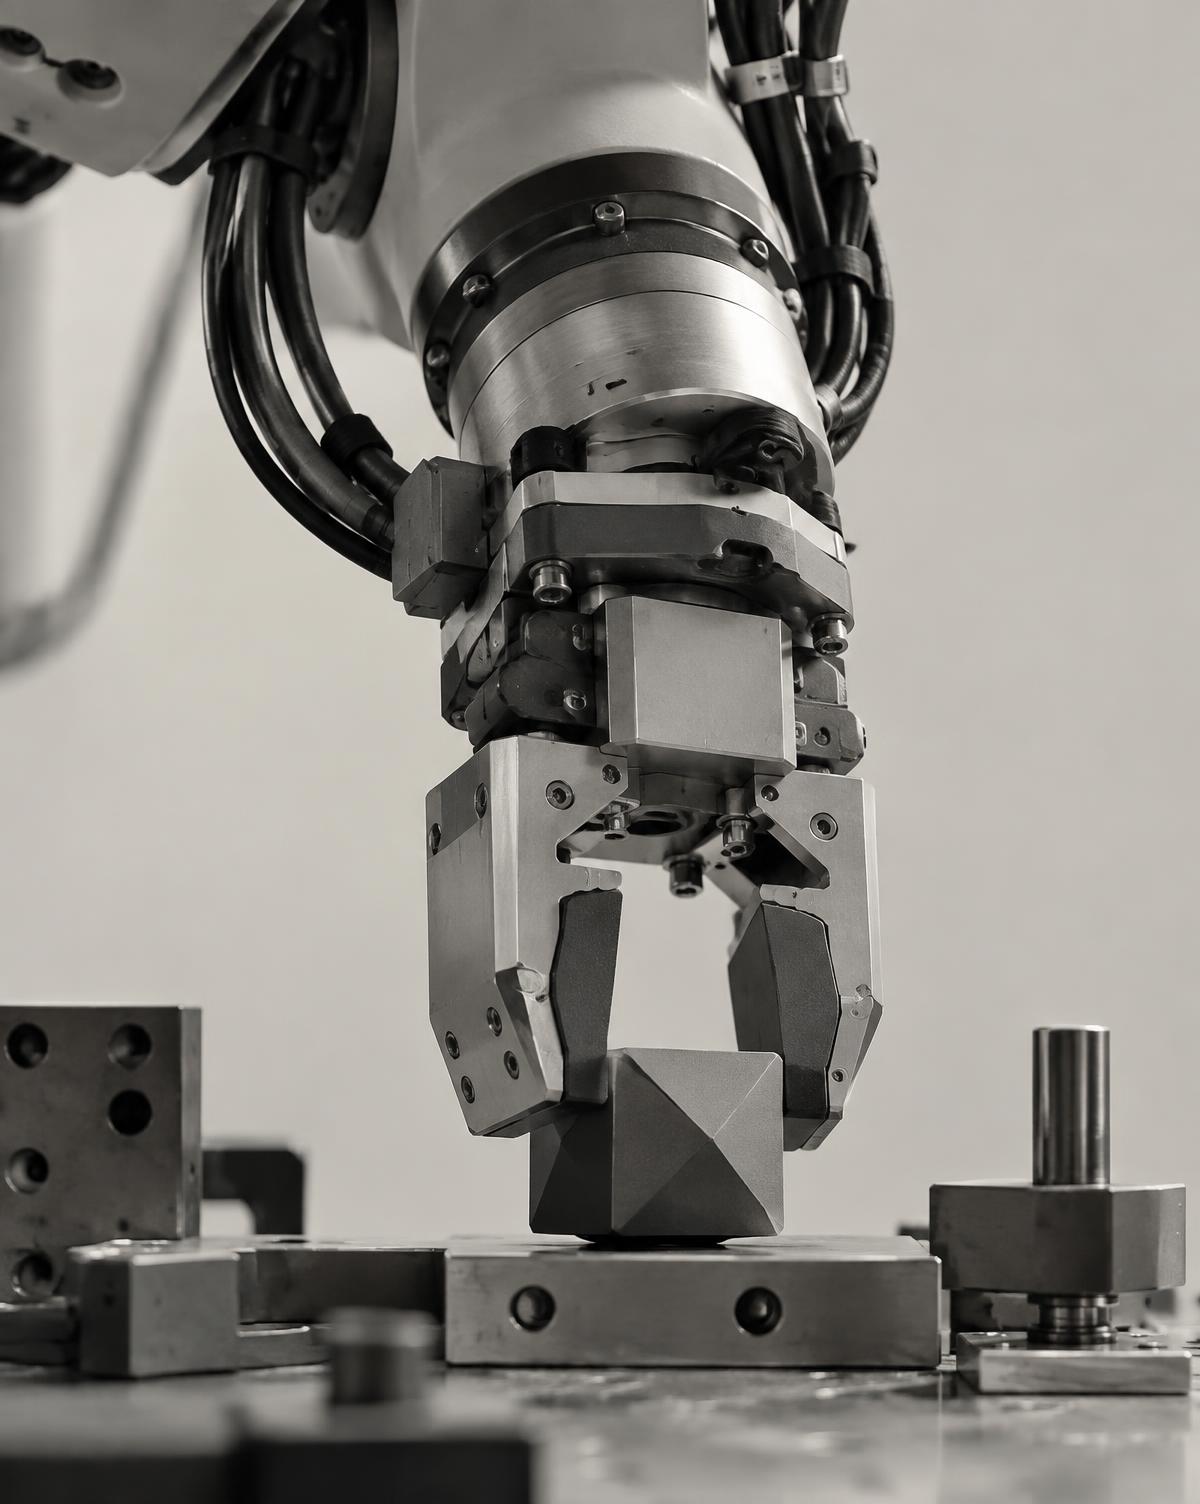
Human motion and manipulation captured from the operator's perspective.
Human interventions when autonomous behavior fails.
Structured outcome labels tied to the episode.
This schema is illustrative and adapts to the receiving training stack.
episode_id string | arraytask_id string | arrayrobot_id string | arrayoperator_id string | arraytimestamp float64camera_streams string | arrayjoint_states string | arrayaction_trace string | arraysuccess booleanfailure_type string | arraytakeover_start string | arraytakeover_end string | arrayrecovery_segment string | arrayqa_status string | array
The initial collection is a fixed operating target. The path beyond it is illustrative and agreed after review.
Describe your robot and receiving stack to shape a relevant demonstration and takeover package.
Define the task, embodiment, success criteria and data requirements.
Record demonstrations, interventions and recovery behavior.
Review synchronization, trajectory integrity, labels and episode quality.
Package data in the format the training stack already reads.
Feed recovery and failure data back into the learning process.